Projects / First prototype

Mini Castus

A fully autonomous prototype designed to demonstrate a down-scaled solution for routine beach clearing. It utilizes a combination of embedded AI, monocular vision, and skid-steer navigation to detect and retrieve small litter like soda cans and cigarette butts from sand. Mini Castus successfully proved the core hardware and software concepts for its successor, Castus Alpha.

  • YOLO
  • Google Coral Edge TPU
  • TFLite
  • Raspberry Pi 4B
  • Arduino Uno R3
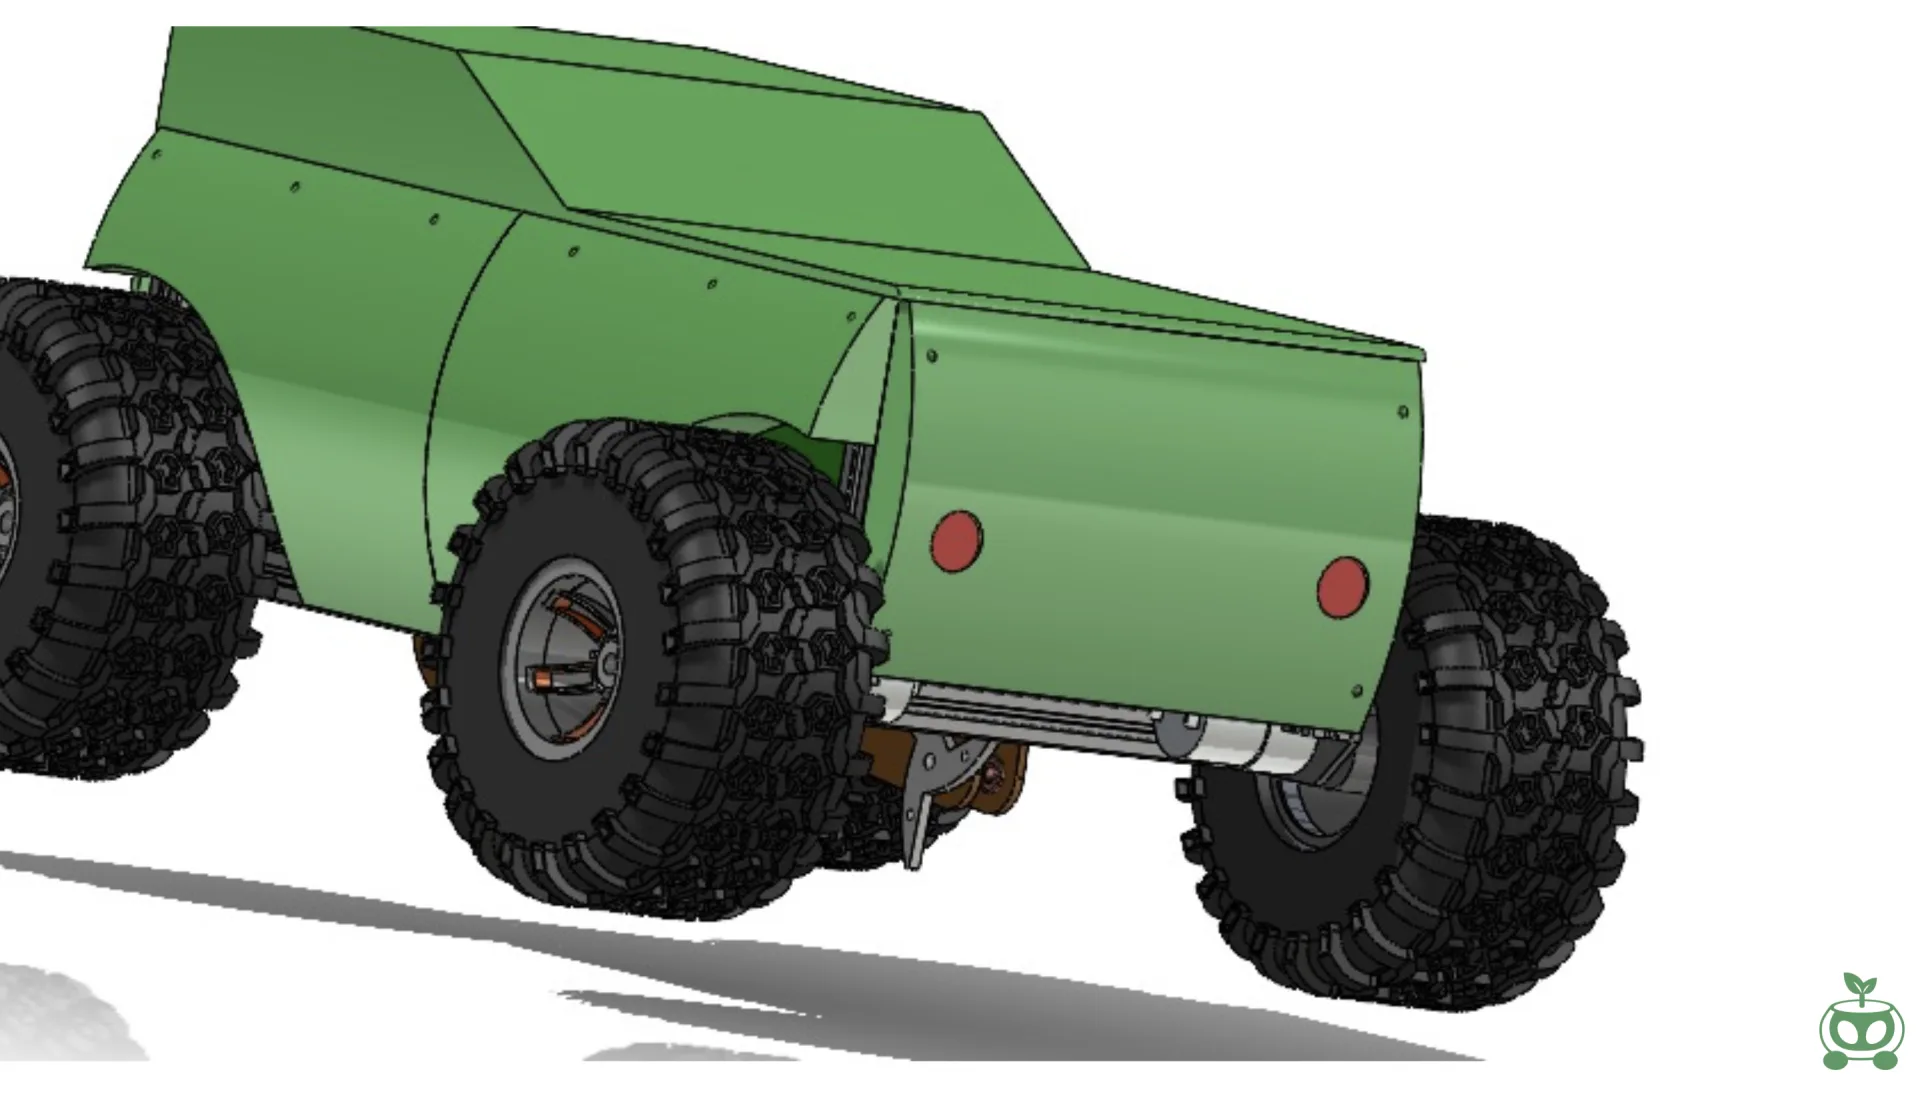
Mini Castus render
Wheel drive
4
Zero-radius skid steering
Battery
12V
Lead-acid power supply
Runtime
~30 min
Continuous operation
Camera
1
Monocular vision system

Under the hood

Technical Specification

Robotics & Power

  • Four-wheel drive with zero-radius skid steering for precise positioning
  • Servo-actuated collection tray with dual high-torque brush motors for sand sifting
  • Powered by a 12V lead-acid battery supporting roughly 30 minutes of continuous operation
  • Actuation controlled via Arduino Uno R3 using custom serial communication protocols

AI & Sensing

  • Monocular vision system using a single USB camera to reduce mechanical complexity
  • Real-time object detection using a YOLO model processed on a Google Coral Edge TPU
  • Obstacle avoidance via TFLite depth map inference
  • Decision-making governed by a deterministic Finite State Machine

Durability

  • Grounded aluminum chassis to prevent short-circuits and electrical hazards
  • Active fan cooling for the Raspberry Pi 4B and dedicated heat sinks for LEDs
  • Multi-stage power converters with current limiting to protect logic boards
  • Electronic switch-controlled, high-power LED indication system for situational awareness